Humanoid Perceptive Locomotion
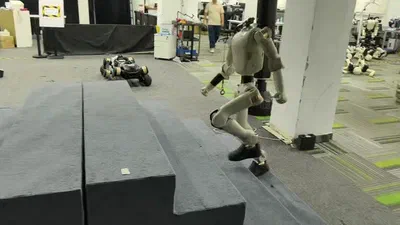
Abstract Train a humanoid robot perceptive locomotion policy using RL. The end-to-end policy receives depth image and proprioceptive observation as input and outputs desired joint …
•
1 min read
Abstract Train a humanoid robot perceptive locomotion policy using RL. The end-to-end policy receives depth image and proprioceptive observation as input and outputs desired joint …