Humanoid Perceptive Locomotion
September 21, 2026
·
1 min read
Abstract
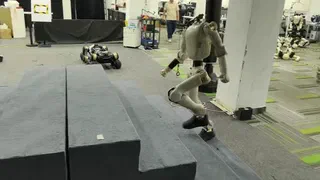
Train a humanoid robot perceptive locomotion policy using RL. The end-to-end policy receives depth image and proprioceptive observation as input and outputs desired joint angles.
Contributions:
- Improvement of AMP (Adversarial Motion Priors) for multiple styles of locomotion in one policy (walking, ascending/descending, running, crossing gaps).
Demo Video

Authors
YasenJia
(he/him)
Robotics Enthusiast
I am a graduate student of BIT(Beijing Institute of Technology, China), majoring in Intelligent Robot and System, supervised by Prof.Yan Huang. Before that, I received my bachelor’s degree in Mechatronical Engineering from BIT.